announced a strategic investment and partnership with Arabic.ai.


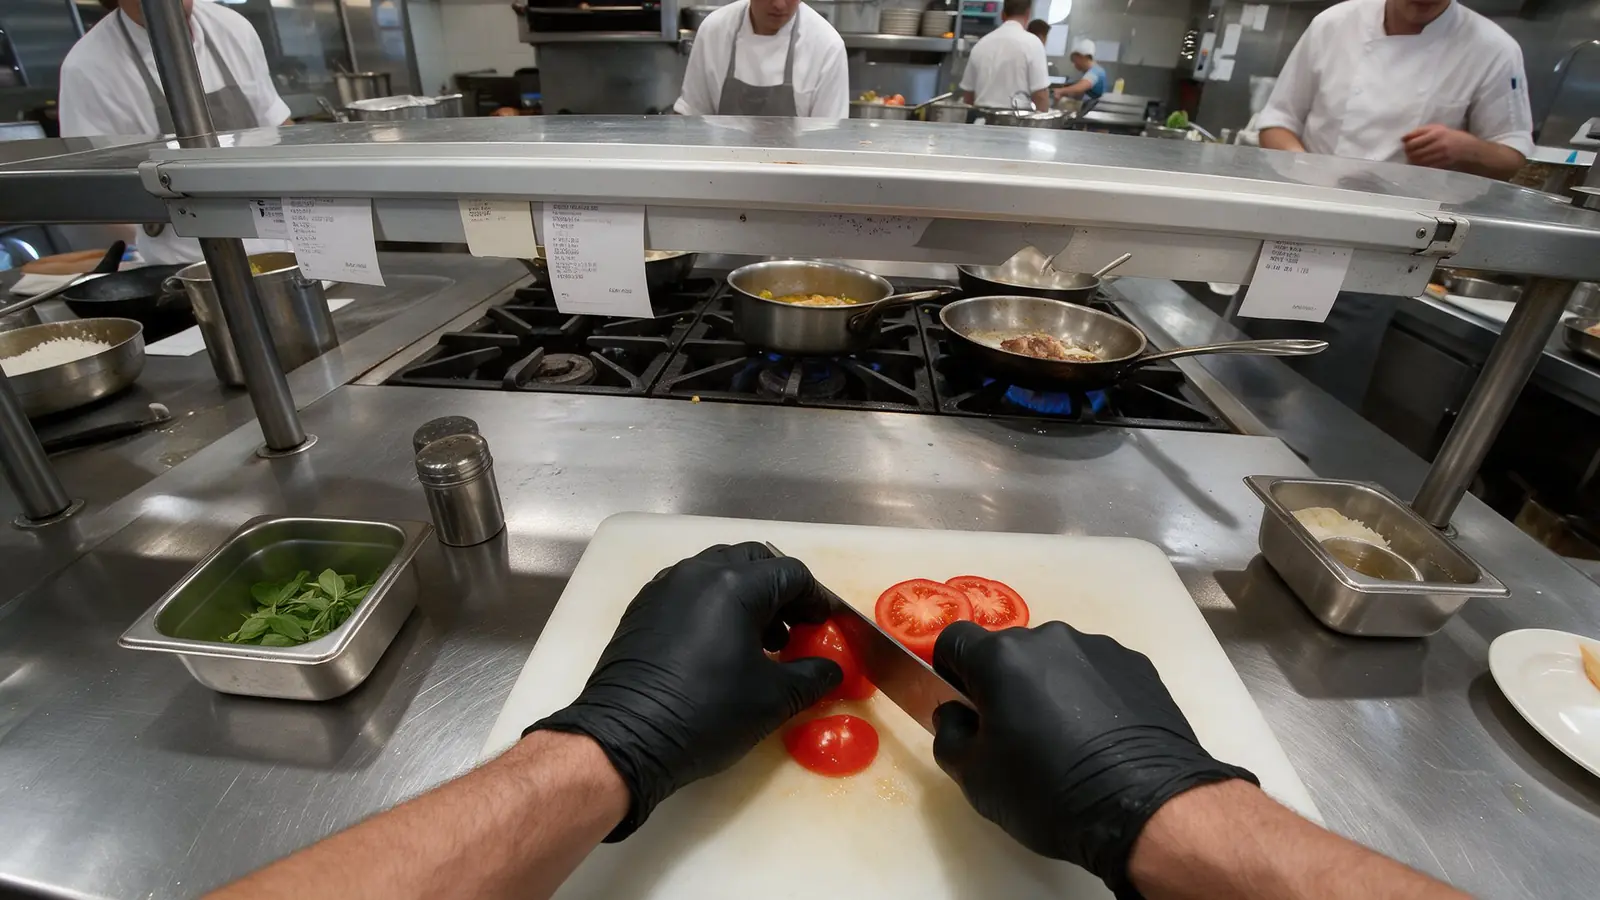
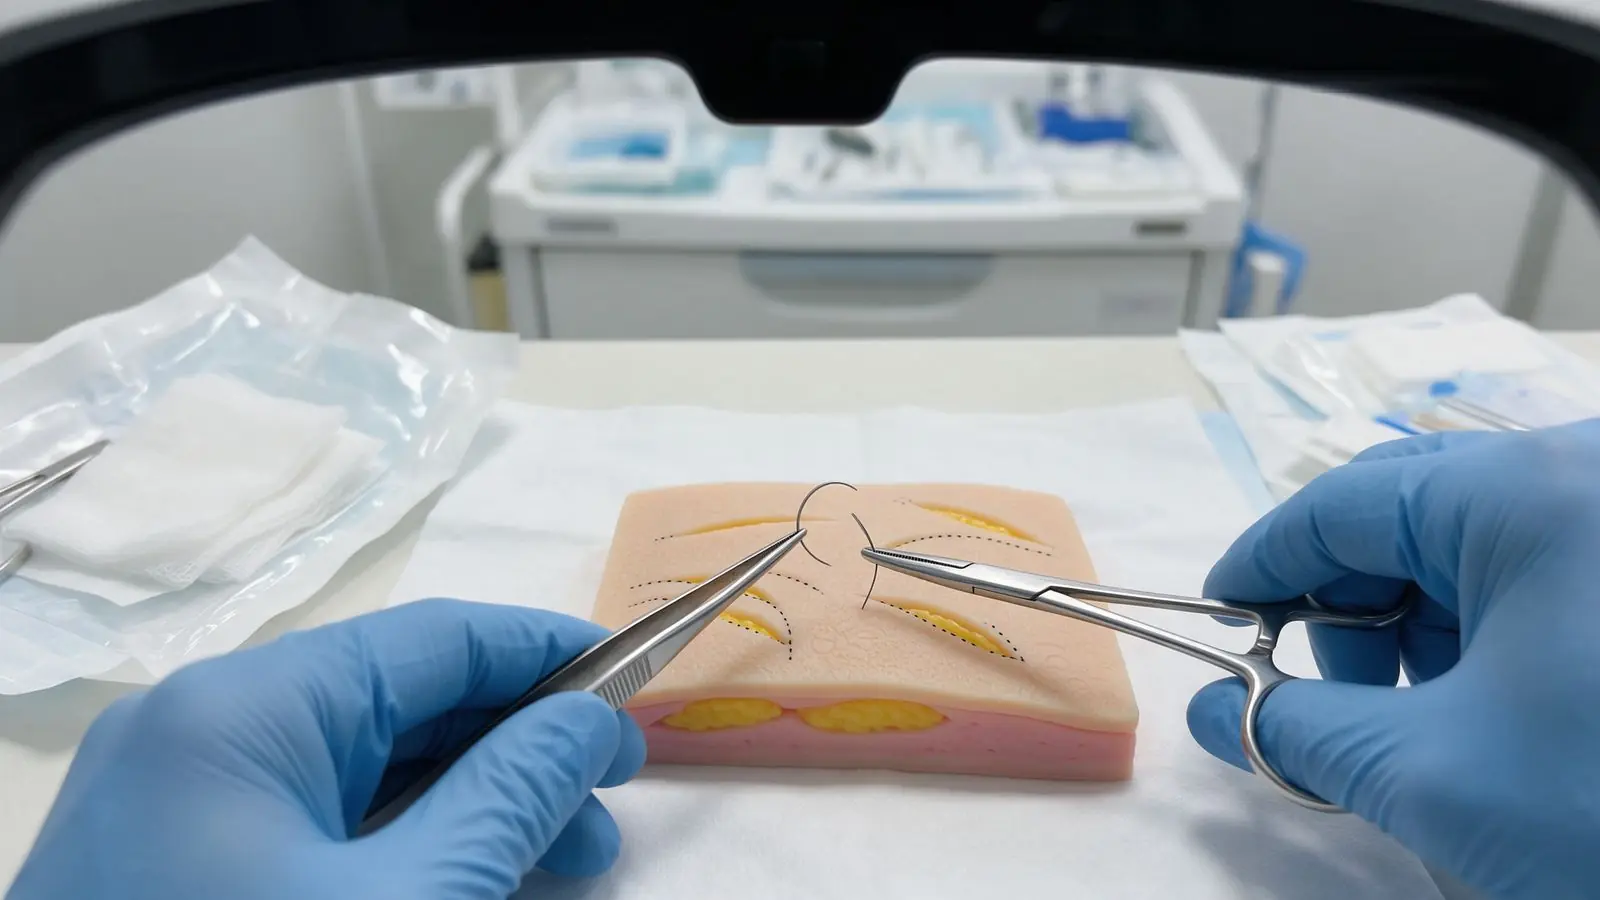
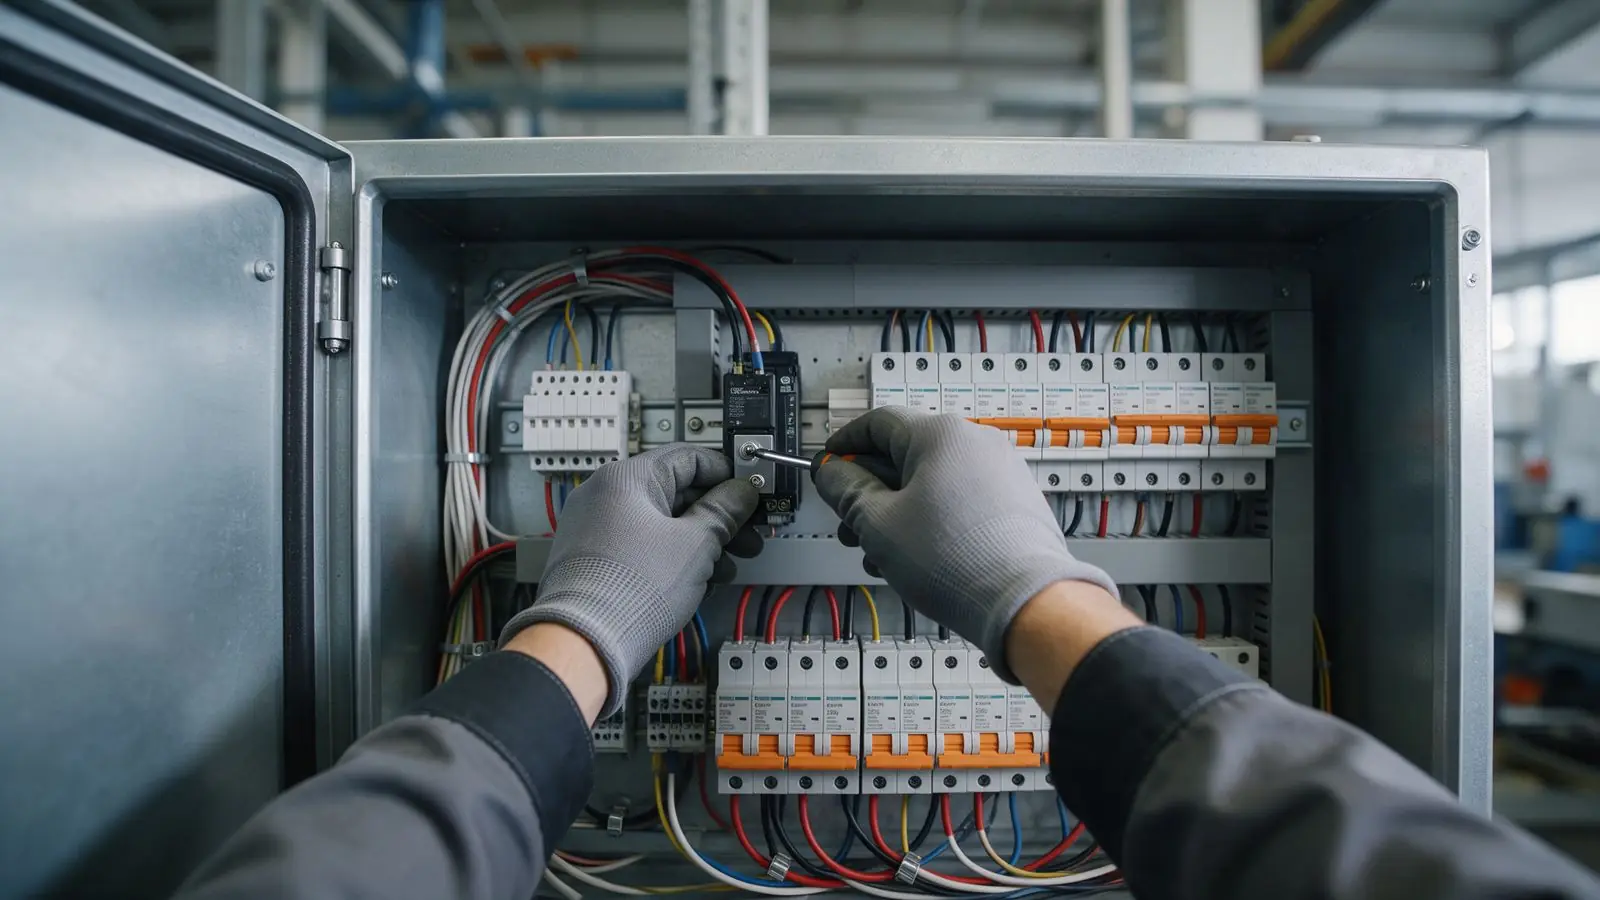
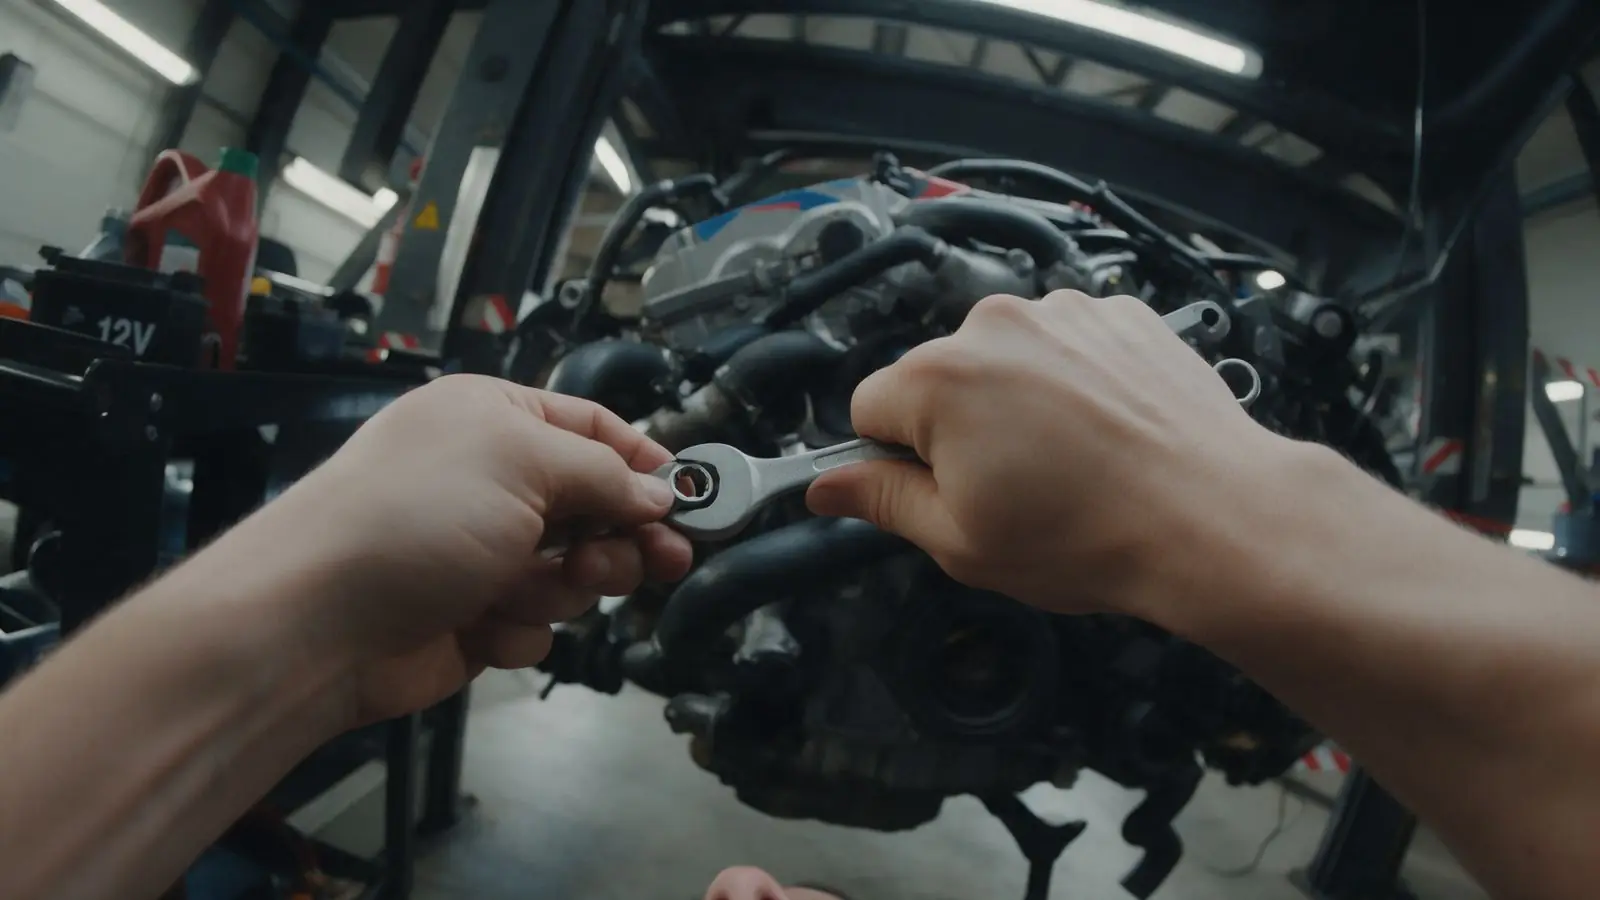

First-person demonstration data for physical AI: video, hand motion and task labels on one clock, recorded by specialists, delivered rights-clean.
Sample episode · 001
See one hour of Arabic.AI data.
One real task, recorded first-person: the video, both hands and every step on a single clock. Drag the timeline to explore it. Ask our team about the full hour.
Every label, box and trace under this clip is timed to its own frames. The hand traces are measured from the video. These specs are an example: final specs are agreed for each project, recorded to your task script.
Filmed where the work happens.
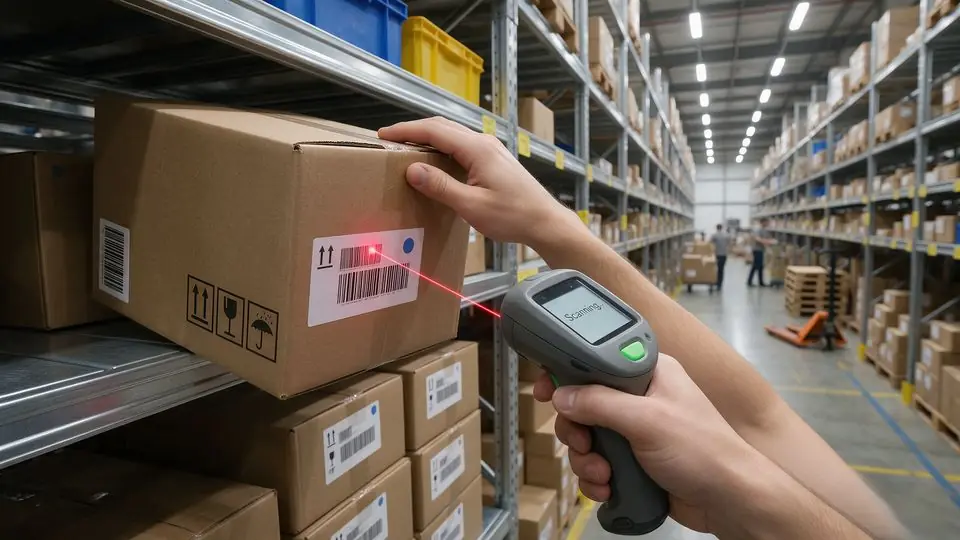
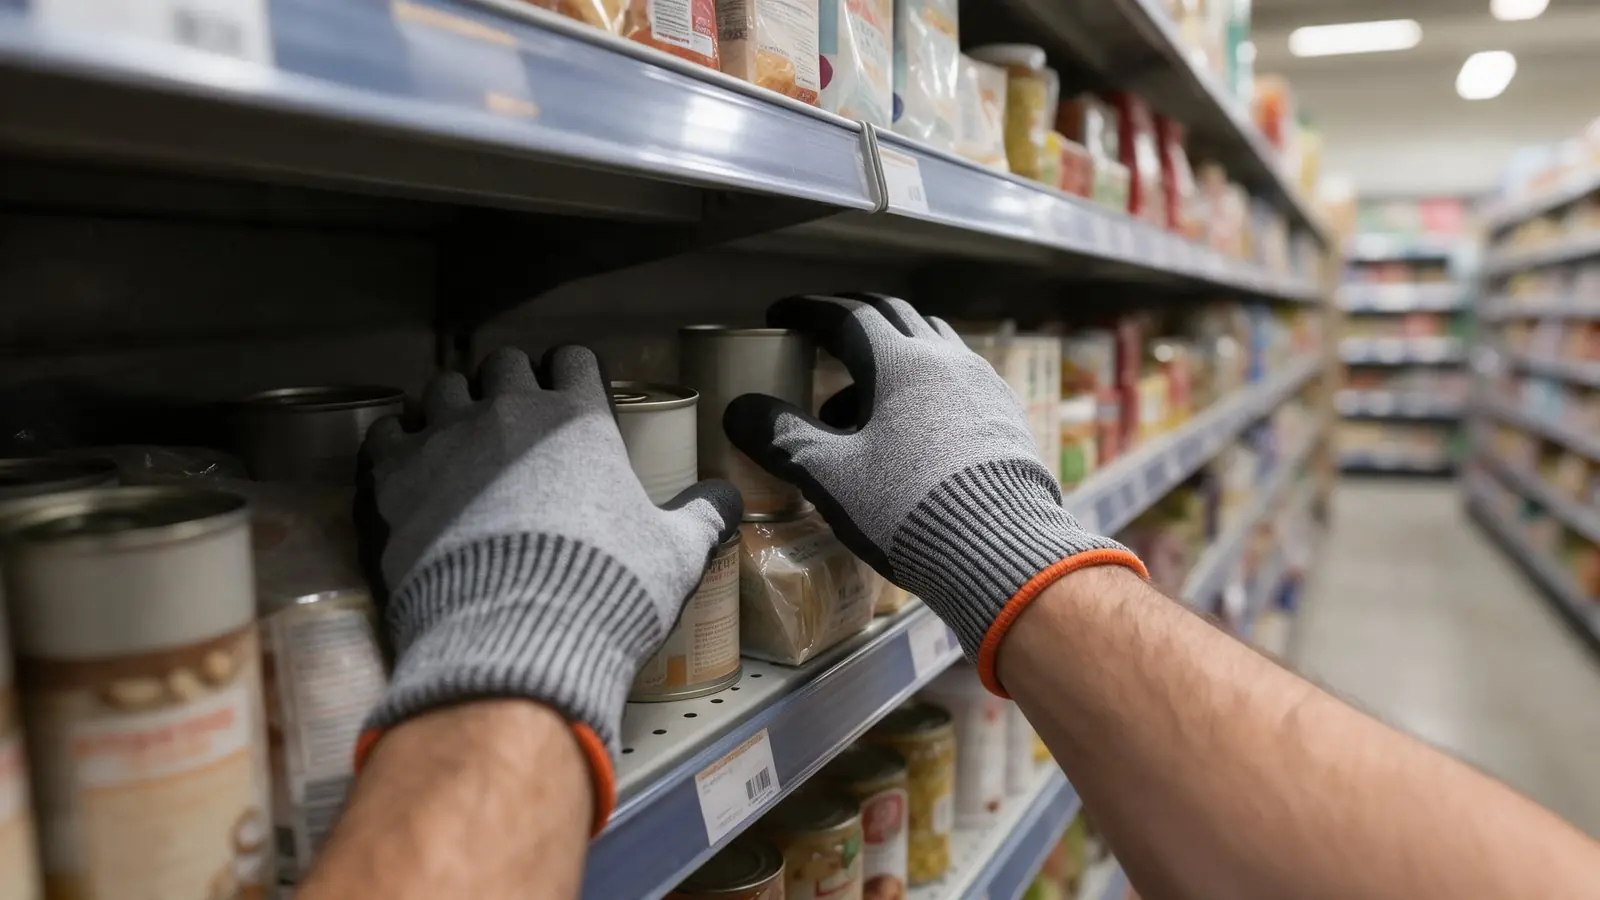
Real sites with releases in place: factories, warehouses, restaurant kitchens, stores, workshops and simulation labs. Your task script decides what is performed; our capture teams decide nothing but the camera.
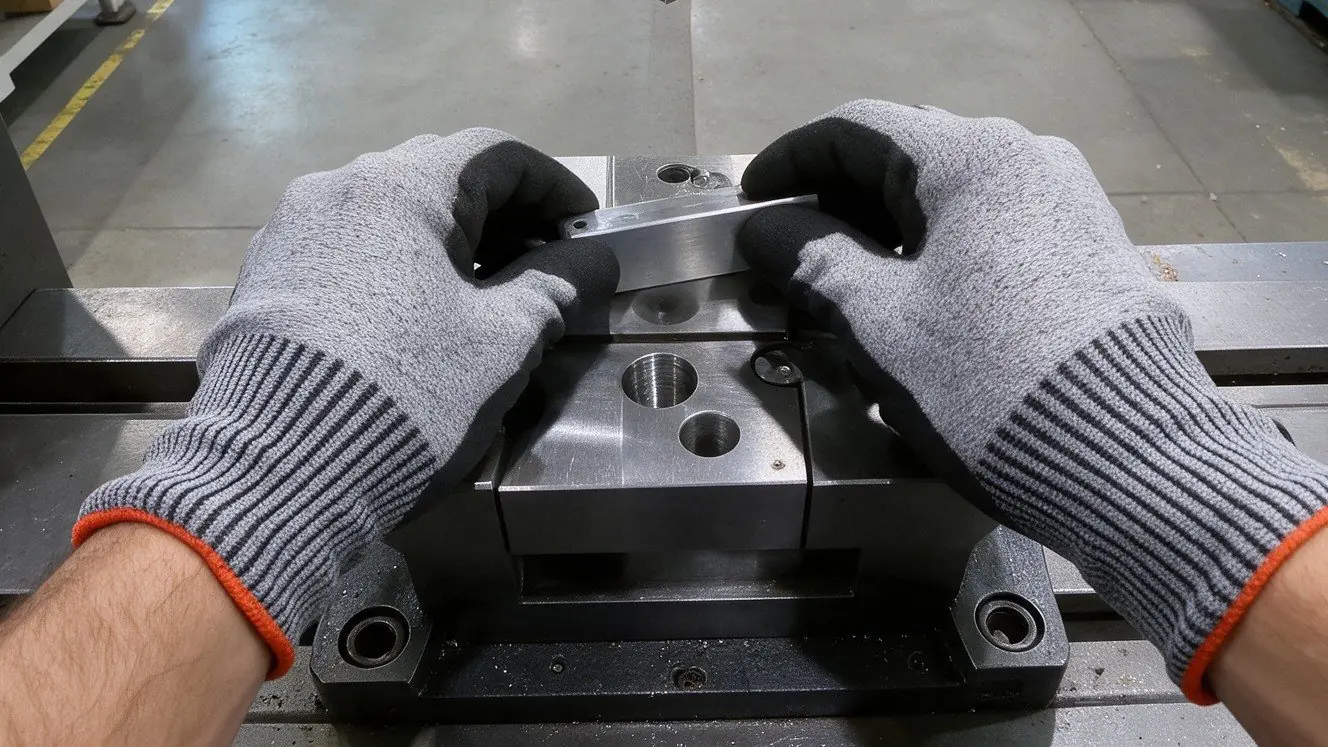
- Factory Assembly, fit and fastening at the bench: alignment, torque, inspection.
- Warehouse Picking, scanning, packing and putting away across racking and docks.
- Restaurant kitchen Prep, line cooking and plating at service speed.
- Retail Shelf stocking, facing and price checks on the shop floor.
- Auto repair Diagnosis and repair in the engine bay, with hand tools and torque.
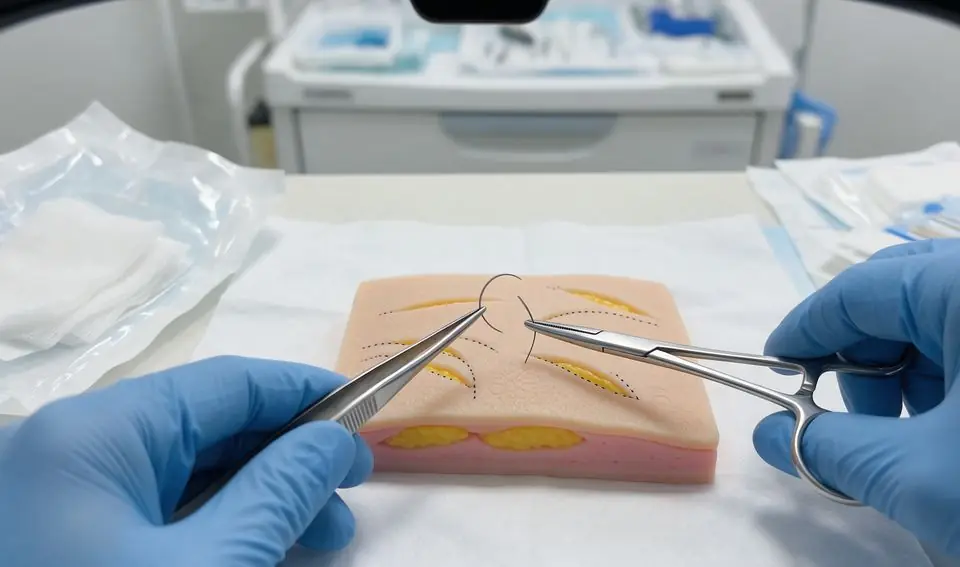
- Healthcare sim Suturing, dressing and instrument handling on training models.
Every frame is data.
Outside the glass, a mechanic tightening a bolt. Inside it, what we deliver: the hands, the tool, the part and the step, labelled on every frame.
Move the glass · click it to change its shape · lensFrom task script to dataset.
A 300-hour pilot across three environments, delivered in your format with a datasheet and consent records.
Task script
Read the step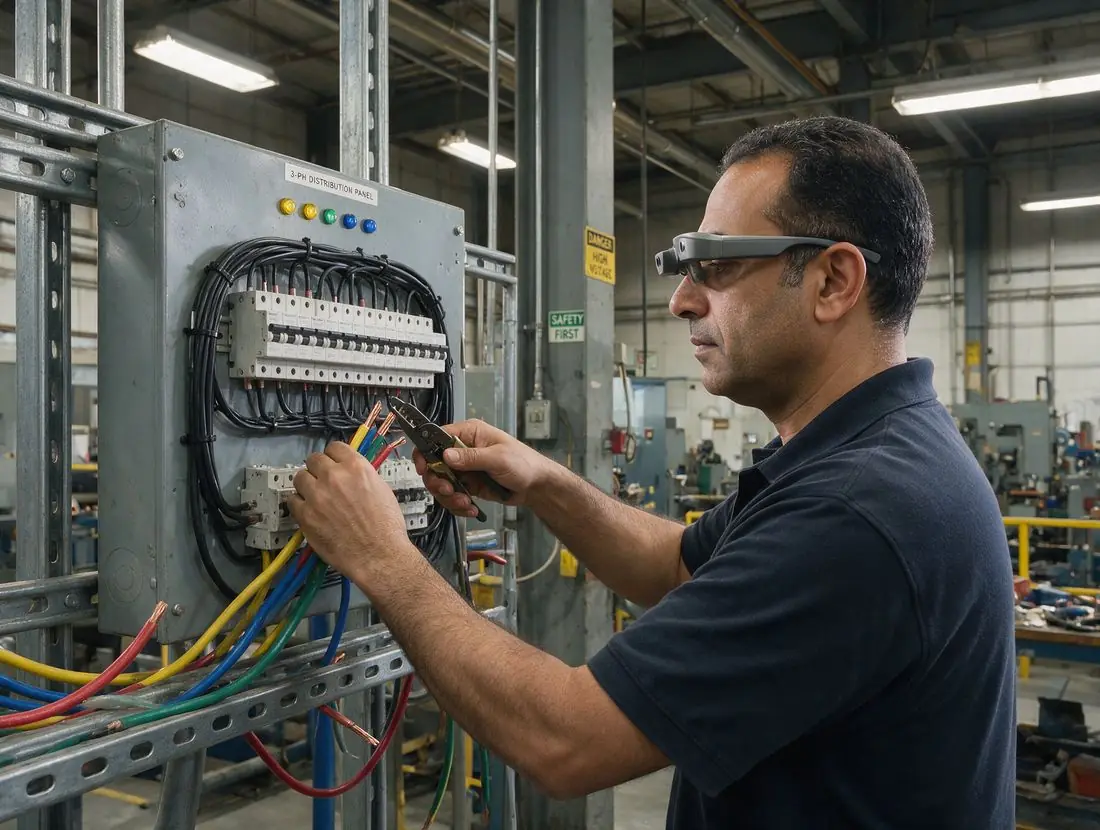
Specialists and consent
Read the step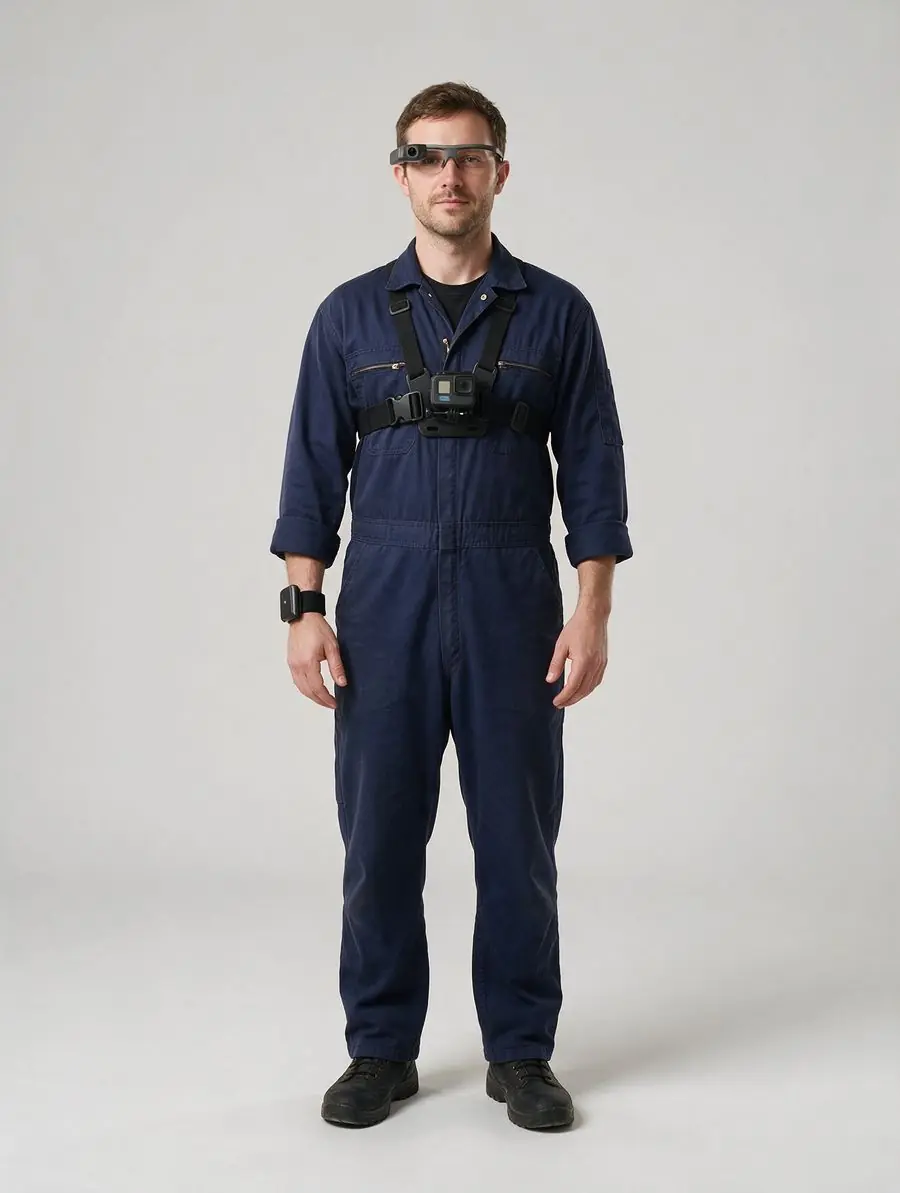
Capture
Read the stepReview and annotation
Read the stepDelivery
Read the stepWhy Arabic.AI
What makes the data usable.
Select a slice to open it.
Anyone can wear a camera. Few can wire a panel or close a wound. We pick people who do the task for a living and brief them on your script.
- Specialists, not a crowd. Anyone can wear a camera. Few can wire a panel or close a wound. We pick people who do the task for a living and brief them on your script.
- Filmed where the work happens. Real sites with releases in place: factories, kitchens, warehouses and workshops, not a studio set.
- Motion and intent, not just pixels. The wrist trace and the step labels ride on the video’s clock, so a model sees what the hand did and why.
- Labelled, frame by frame. Steps, hands, tools and objects on one clock, with boxes and keypoints on annotated projects.
- Rights-clean before it ships. Signed releases, blurred faces and a consent ID on every clip. Ready for your legal review on day one.
- Delivered in your format. LeRobot, RLDS or MCAP, with checksums, a datasheet and the consent records in every drop.
Three tiers, one pipeline.
Consent and rights.
Physical AI is part of Arabic.AI Data Services: collection, labeling and curation under one consent record.
With every clip
- A signed contributor releaseIn the contributor’s own language, naming the use: training machine-learning models, with the right to sublicense to your organisation.
- A site releaseFor every workshop, kitchen, store or lab we film in.
- A consent IDIn the metadata sidecar, so any clip traces to its paperwork and can be withdrawn if a contributor asks.
- A datasheetWhat was collected, where, under which script, with known gaps stated.
What we never do
- Film anyone under 18, or anyone who has not signed.
- Scrape, buy or resell footage we did not record ourselves.
- Film in public spaces without a site release.
- Reuse a dataset collected under an exclusive agreement for another customer.
Questions labs ask.
Who owns the data?
You do, under the licence in your agreement. Exclusive collection is available: a dataset recorded under an exclusive agreement is never reused for another customer.
Can we send our own task script and format?
Yes, and we prefer it. Send the tasks, the camera placement, the label taxonomy and the file format you train on; we return a task script for approval and deliver in your format.
How is hand motion captured?
A wrist IMU on each hand at 100 Hz, timestamped on the same clock as the glasses and the chest camera, delivered raw as CSV. Finger-level pose comes on annotated projects as estimated keypoints from the video, marked as estimated.
How long does a pilot take?
It depends on your task script, the environments and the hours you need. Whether it's a 300-hour pilot across three environments or a different scope, we give you a timeline once the scope is agreed with our team.
Do you offer teleoperation data?
Not yet at scale. Teleoperation rigs for robot-arm demonstrations are planned next, after pilots on the three tiers above. If your lab needs it, tell us and we will plan the rig around your platform.
How is a project quoted?
By tier, on your task script. Talk to our team for a quote, including a 50-hour starter dataset.
With every delivery
Three promises in one folder.
Each file inside is something that ships with the data. Click one to read it.
- One clock Video, motion and labels timestamped together, so a frame, a wrist reading and a step name always agree.
- Your spec, our capture Task script, label taxonomy and file format are yours; the kit, the calibration and the people are ours.
- Rights, registered Every clip carries a consent ID that traces to a signed release. Nothing ships that cannot be traced.
Start with a 50-hour dataset.
Recorded to your task script and scoped with our team.
Figures are confirmed per task script.